Shift Sources and Modes
RobustRLlib declares a deployment shift as data. One shift is a perturbation configuration, the tuple (source, factor, mode, magnitude, resampling rule, optional schedule, seed): the source says where the intervention enters the loop, the factor what it perturbs, the mode how it is built, the magnitude how far it departs from nominal, the resampling rule and the schedule how it evolves within an episode, and the seed makes its draws reproducible. A shifted environment is a base task with one wrapper per configuration, and the task code is not modified.
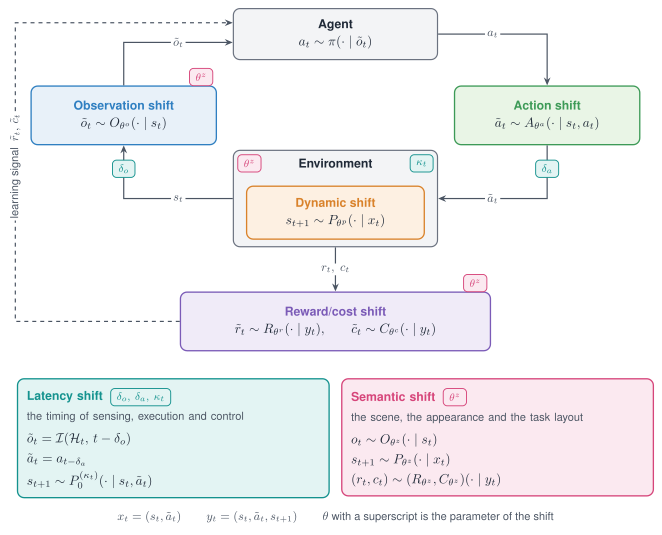
The six shift sources on the loop between agent and environment, in the notation of the paper. Four of them act on one component of the loop. The Latency shift and the Semantic shift act at several points, which the small tags mark.
Summary
| Aspect | Shift sources and modes |
|---|---|
| Interface | make_robust(env_id, shifts=[...], seed=...) returns an environment with the standard reset and step |
| Configuration | (source, factor, mode, magnitude, resampling rule, optional schedule, seed); see Perturbation configuration |
| Declaration | ShiftSpec(target, mode, params, schedule, seed), which writes the seven fields, or the same keys in YAML |
| Sources | Six shift sources, written with eight targets |
| Modes | Five modes, written with 22 mode names, the schedule field and the list of shifts |
| Evaluation | A grid condition is a list of perturbation configurations; see Evaluation Protocol |
| Factors | One parameter name evaluated at several magnitudes; see Add a new shift factor |
| Simulators | MuJoCo, Box2D and robosuite; see Add a physics simulation |
Shift sources
A shift source names the component of the decision process that is perturbed.
| Shift | What it perturbs | Target in code | Page |
|---|---|---|---|
| Dynamic shift | Physical parameters, external forces, the simulator state | dynamics, transition |
Dynamic shift |
| Observation shift | The observation returned to the policy | observation |
Observation shift |
| Action shift | The action between policy and simulator | action |
Action shift |
| Reward/cost shift | The reward, or a cost field in info |
reward, cost |
Reward/cost shift |
| Latency shift | When actions, observations and rewards arrive | latency |
Latency shift |
| Semantic shift | Colours, lights, cameras and object positions | appearance; dynamics for position offsets |
Semantic shift |
The definitions of the figure, one shift source per row:
| Shift | Definition |
|---|---|
| Dynamic shift | 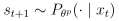 |
| Observation shift | 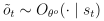 |
| Action shift | 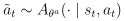 |
| Reward/cost shift | 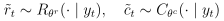 |
| Latency shift | 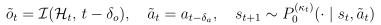 |
| Semantic shift | 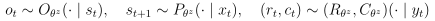 |
A parameter with a superscript belongs to one shift source. Setting every parameter to its nominal value gives back the nominal task.
Shift modes
A mode names how the intervention is built. Three modes are selected by the mode name of a
shift; the other two are selected by the schedule field and by the list of shifts.
| Mode | How the intervention is built | How it is declared | Page |
|---|---|---|---|
| Stochastic | Drawn from the seeded random generator of the wrapper | A mode name such as gauss or uniform |
Stochastic |
| Adversarial | Computed from the current observation or action to counter the policy | The mode name adversarial, or oppose, rotate, oppose_goal |
Adversarial |
| Parametric | Fixed by the parameters | A mode name such as scale, set or shift |
Parametric |
| Non-stationary | A stationary shift whose intensity follows a schedule within the episode | The schedule field |
Non-stationary |
| Composition | Several shifts acting at once | The order of the shifts list |
Composition |
Sources by mode
Each cell lists the mode names that the code accepts. The last column lists the mode names that read a schedule. Composition applies to every shift.
| Shift | Stochastic | Adversarial | Parametric | Non-stationary |
|---|---|---|---|---|
| Dynamic shift | gauss, uniform, loguniform, push; gauss on the target transition |
none | scale, set, translate |
scale, translate, push; gauss on transition |
| Observation shift | gauss, uniform, relative, bias |
adversarial |
shift |
all six mode names |
| Action shift | gauss, uniform |
adversarial, oppose, rotate, oppose_goal |
shift |
all seven mode names |
| Reward/cost shift | gauss, uniform |
none | shift |
gauss, uniform, shift |
| Latency shift | buffer, substep, interp |
none | fixed, delay |
substep, interp |
| Semantic shift | gauss, uniform, loguniform |
none | hue, tint, swap, scale, set, translate |
hue, tint, swap, scale, translate |
Perturbation configuration
Each field of the tuple is written by one part of a ShiftSpec. The factor and the magnitude are
parameters of the mode name, and the resampling rule follows from the mode name.
| Field | What it says | In ShiftSpec |
Gravity × 1.3 on Hopper |
|---|---|---|---|
| Source | Where the intervention enters the loop | target: six sources, written with eight targets |
"dynamics" |
| Factor | What it perturbs | param and index for a physical, light or camera parameter; body for a push; geoms for a colour; keys or info_key for one entry of an observation or a cost; otherwise the whole signal |
"param": "gravity" |
| Mode | How the intervention is built | mode, one of 22 mode names |
"scale" |
| Magnitude | How far it departs from nominal, in the units of the operator | The value parameters of the mode name, such as factor, value, offset, sigma, low and high, eps, degrees, steps or force |
"factor": 1.3 |
| Resampling rule | Whether a value is redrawn at every step, held for an episode, or fixed | Set by the mode name, see Resampling rules; resample: "step" on the latency mode names buffer and interp |
Fixed |
| Schedule | Optional; when the intervention is active and how its magnitude evolves | schedule; None is stationary |
None |
| Seed | Makes the draws reproducible | seed, else the seed passed to make_robust |
None |
Resampling rules
The mode name fixes when a value is drawn. A schedule then multiplies the magnitude by a value that changes within the episode.
| Resampling rule | Mode names |
|---|---|
| Per step | gauss, uniform and relative on observations, actions, rewards and costs; gauss on transition; adversarial, oppose, rotate and oppose_goal, computed from the current observation or action |
| Per policy decision | substep: one control period per action, at a rate drawn per episode |
Per episode, at reset |
bias; gauss, uniform and loguniform on dynamics and appearance; buffer and interp, unless resample is "step" |
| Per event | push: the phase of the first push is drawn per episode, the direction per push |
| Fixed | shift, scale, set, translate, hue, tint, swap, fixed and delay |
Declare a shift
from robustrllib import make_robust, ShiftSpec

env = make_robust(
    "Hopper-v5",
    shifts=[ShiftSpec("dynamics", "scale", {"param": "gravity", "factor": 1.3})],
    seed=0,
)
obs, info = env.reset(seed=0)
obs, reward, terminated, truncated, info = env.step(env.action_space.sample())
| Field | Type | Default | Meaning | Field of the configuration |
|---|---|---|---|---|
target |
str | required | Where the shift acts; one of the eight targets | Source |
mode |
str | required | The mode name | Mode, and with it the resampling rule |
params |
dict | empty | Parameters of the mode name; listed on the page of each shift | Factor and magnitude |
schedule |
dict | None |
Declares the Non-stationary mode | Schedule |
seed |
int | None |
A seed for this shift alone | Seed |
One declaration per shift source:
GEOMS = ["torso_geom", "thigh_geom", "leg_geom", "foot_geom"]
SOURCES = {
    "Dynamic shift":     ShiftSpec("dynamics", "scale", {"param": "gravity", "factor": 1.3}),
    "Observation shift": ShiftSpec("observation", "gauss", {"sigma": 0.05}),
    "Action shift":      ShiftSpec("action", "gauss", {"sigma": 0.1, "clip_first": True}),
    "Reward/cost shift": ShiftSpec("reward", "shift", {"shift": -0.5}),
    "Latency shift":     ShiftSpec("latency", "fixed", {"steps": 2}),
    "Semantic shift":    ShiftSpec("appearance", "hue", {"geoms": GEOMS, "degrees": 60}),
}
The same action sequence under each shift shows what each source touches: the observations, the rewards, or neither.
import numpy as np


def rollout(shifts, steps=10):
    env = make_robust("Hopper-v5", shifts=shifts, seed=0)
    obs, _ = env.reset(seed=0)
    actions = np.random.default_rng(0).uniform(-1, 1, size=(steps, 3))
    trace, rewards = [obs], []
    for action in actions:
        obs, reward, *_ = env.step(action)
        trace.append(obs)
        rewards.append(reward)
    env.close()
    return np.array(trace), np.array(rewards)


ref_obs, ref_rew = rollout([])
for name, spec in SOURCES.items():
    obs, rew = rollout([spec])
    print(f"{name:18s} largest change of an observation = {np.abs(obs - ref_obs).max():5.3f}   "
          f"change of the summed reward = {np.sum(rew - ref_rew):+6.3f}")
Dynamic shift      largest change of an observation = 0.510   change of the summed reward = -0.108
Observation shift  largest change of an observation = 0.121   change of the summed reward = +0.000
Action shift       largest change of an observation = 0.347   change of the summed reward = +0.147
Reward/cost shift  largest change of an observation = 0.000   change of the summed reward = -5.000
Latency shift      largest change of an observation = 3.825   change of the summed reward = -1.441
Semantic shift     largest change of an observation = 0.000   change of the summed reward = +0.000
The Semantic shift changes colours only. The observation of Hopper-v5 is a state vector, so
this source matters for policies that read rendered images.
Extra keyword arguments of make_robust reach the task constructor.
env = make_robust("Hopper-v5", shifts=[SOURCES["Dynamic shift"]], seed=0,
                  terminate_when_unhealthy=False)
Tip
Neither import robustrllib nor make_robust reads the command line. A script may parse
arguments of its own before or after it builds environments.
Declare a shift in YAML
A shift list is plain data. RobustConfig holds an environment id, a seed, constructor
arguments and a list of shifts.
env_id: Hopper-v5
seed: 0
make_kwargs: {max_episode_steps: 1000}
shifts:
  - {target: dynamics, mode: scale, params: {param: gravity, factor: 1.3}}
  - {target: observation, mode: gauss, params: {sigma: 0.05}}
from robustrllib import load_config

env = load_config("hopper_shifted.yaml").make()
The same dictionary form is used for the conditions of an evaluation grid.
- name: gravity_1.3+obs_noise
  shifts:
    - {target: dynamics, mode: scale, params: {param: gravity, factor: 1.3}}
    - {target: observation, mode: gauss, params: {sigma: 0.1}}
Inspect the stack
Printing the environment lists the wrappers from the outside in.
env = make_robust("Hopper-v5", shifts=[
    SOURCES["Dynamic shift"], SOURCES["Observation shift"], SOURCES["Action shift"],
], seed=0)
print(env)
<ActionShift<ObservationShift<DynamicsShift<RobustCoreWrapper<TimeLimit<OrderEnforcing<PassiveEnvChecker<HopperEnv<Hopper-v5>>>>>>>>>
| Layer | Role |
|---|---|
HopperEnv |
The task |
PassiveEnvChecker, OrderEnforcing, TimeLimit |
Added by the environment registry |
RobustCoreWrapper |
Added once by the pipeline; switches off the perturbation code built into the task |
DynamicsShift, ObservationShift, ActionShift |
One wrapper per shift, in list order |
Each shift wrapper holds its specification in _spec.
declared = []
layer = env
while hasattr(layer, "env"):
    spec = getattr(layer, "_spec", None)
    if spec is not None:
        declared.append((spec.target, spec.mode))
    layer = layer.env
print(declared)
[('action', 'gauss'), ('observation', 'gauss'), ('dynamics', 'scale')]
Note
The returned object is an instance of robustrllib.gym.Env, not of gymnasium.Env.
robustrllib.compat.as_gymnasium(env) returns a native one for trainers that check the
type.
Declaration rules
- A shift is declared once, at construction, and never passed through
step. - The target and the mode name are names from the tables above, and the pair is one the target accepts.
ShiftSpecchecks names only; an unsupported pair is rejected by the wrapper when the environment is built, at the firstresetor at the firststep, depending on the target.- A new environment is reset and stepped once before a long run.
- The list order is the stacking order, and the first shift sits closest to the task.
- Seeds are passed to
make_robustand toreset, so that every shift is reproducible.