Dynamic shift
A Dynamic shift changes how the world moves. It edits a physical parameter of the simulator, applies an external force to a body, or perturbs the simulator state between steps.
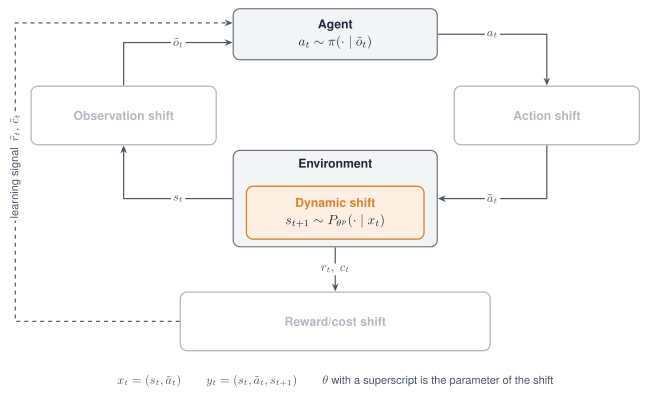
The Dynamic shift acts inside the environment: the next state is drawn from a shifted transition.
Properties
| Aspect | Dynamic shift |
|---|---|
| Perturbs | Physical parameters, external forces, the simulator state |
| Targets in code | dynamics and transition |
| Modes | Stochastic, Parametric, Non-stationary, Composition |
| Factors | A physical parameter named by param and index, a pushed body, or the simulator state |
| Resampling rule | Per episode for gauss, uniform and loguniform; per event for push; per step for noise on transition; fixed for scale, set and translate |
| Acts on a frozen policy | Yes |
| Simulators | MuJoCo for every mode name; Box2D for parameter edits |
Supported modes
| Mode | Mode name in code | What it does |
|---|---|---|
| Stochastic | gauss, uniform, loguniform |
Draws a factor once per episode and multiplies the nominal value by it |
| Stochastic | push |
Applies a force to one body for a few steps, at regular intervals, with a drawn direction and phase |
| Stochastic | gauss on the target transition |
Adds Gaussian noise to positions and velocities after every step |
| Parametric | scale |
Sets the parameter to its nominal value times a factor |
| Parametric | set |
Sets the parameter to an absolute value |
| Parametric | translate |
Adds an offset in metres to a position |
| Non-stationary | schedule on scale, translate, push and transition |
Varies the factor, offset, force or noise within the episode |
| Composition | Several shifts in one list | Edits several parameters at once |
The target transition accepts only the mode name gauss; any other mode name raises
ValueError when the environment is built. The Adversarial mode is not defined for this shift.
Parameters
param and index name the factor, and the parameters of the mode name set its magnitude.
Parameter edits on the target dynamics:
| Mode name | Parameter | Type | Default | Meaning |
|---|---|---|---|---|
all but push |
param |
str | required | Name of the physical parameter |
index |
int, str or "all" |
None |
Entity by position or by name, or every entity | |
scale |
factor |
float | 1.0 |
Factor on the nominal value |
set |
value |
float or list | required | Absolute value |
gauss |
mu, sigma |
float | 1.0, 0.1 |
Mean and standard deviation of the factor |
uniform |
low, high |
float | 0.8, 1.2 |
Bounds of the factor |
loguniform |
low, high |
float | 0.8, 1.2 |
Bounds of a factor drawn uniformly in log space; both positive |
gauss, uniform, loguniform |
operation |
str | "scale" |
With "set" the drawn number is the value itself |
nominal |
float | required with "set" |
The value a schedule multiplier of 0 maps to | |
translate |
offset |
list of float | required | Offset in metres |
External force and state noise:
| Mode name | Parameter | Type | Default | Meaning |
|---|---|---|---|---|
push |
body |
str | "torso" |
Body that receives the force |
interval |
int | 200 |
Control steps between the onsets of two pushes | |
duration |
int | 10 |
Control steps a push lasts | |
force |
float | 50.0 |
Magnitude in newtons | |
direction |
str or list | "random_xy" |
"random_xy", "random_x", or a fixed vector of three numbers |
|
gauss on transition |
q_sigma |
float | sigma, else 0.0 |
Standard deviation of the noise on positions |
v_sigma |
float | sigma, else 0.0 |
Standard deviation of the noise on velocities |
Names of physical parameters on MuJoCo tasks:
param |
Edits |
|---|---|
gravity, wind |
One component of the gravity or wind vector; by default the vertical component of gravity |
body_mass, body_inertia |
Mass of a body; first component of its inertia |
body_pos, body_pos_xyz |
Vertical component, or the full vector, of the offset of a body from its parent; the full vector scales limb length |
dof_damping, dof_frictionloss |
Damping and dry friction of a joint |
geom_friction |
Sliding friction of a geom |
geom_size, geom_size_xyz |
First size component, or the full size vector, of a geom |
actuator_gear |
Gear of an actuator, its control authority |
freejoint_pos |
Position of a free-floating body |
Box2D tasks use the names gravity, enable_wind, wind_power, turbulence_power,
main_engine_power, side_engine_power, engine_power and friction.
Declare the shift
Every example on this page passes the check below.
from robustrllib import make_robust, ShiftSpec


def check(spec, env_id="Hopper-v5"):
    env = make_robust(env_id, shifts=[spec], seed=0)
    env.reset(seed=0)
    env.step(env.action_space.sample())
    env.close()
Parametric:
PARAMETRIC = {
    "scale":     ShiftSpec("dynamics", "scale", {"param": "body_mass", "index": "torso", "factor": 1.5}),
    "set":       ShiftSpec("dynamics", "set", {"param": "dof_frictionloss", "index": "all", "value": 0.5}),
    "translate": ShiftSpec("dynamics", "translate", {"param": "body_pos_xyz", "index": "foot",
                                                     "offset": [0.06, 0.0, 0.0]}),
}
Stochastic:
STOCHASTIC = {
    "gauss":      ShiftSpec("dynamics", "gauss", {"param": "gravity", "mu": 1.0, "sigma": 0.05}),
    "uniform":    ShiftSpec("dynamics", "uniform", {"param": "actuator_gear", "index": "all",
                                                    "low": 0.8, "high": 1.2}),
    "loguniform": ShiftSpec("dynamics", "loguniform", {"param": "dof_damping", "index": "all",
                                                       "low": 0.5, "high": 2.0}),
    "absolute":   ShiftSpec("dynamics", "uniform", {"param": "dof_frictionloss", "index": "all",
                                                    "operation": "set", "nominal": 0.0,
                                                    "low": 0.0, "high": 1.0}),
    "push":       ShiftSpec("dynamics", "push", {"body": "torso", "interval": 250, "duration": 12,
                                                 "force": 60.0, "direction": "random_x"}),
    "transition": ShiftSpec("transition", "gauss", {"q_sigma": 0.001, "v_sigma": 0.01}),
}
Non-stationary, with the factor range written into the schedule:
NON_STATIONARY = ShiftSpec(
    "dynamics", "scale", {"param": "actuator_gear", "index": "all", "factor": 1.0},
    schedule={"type": "sine", "start": 0.8, "end": 1.2, "period": 200},
)
Composition, and the values it writes into the model:
env = make_robust("Hopper-v5", shifts=[
    ShiftSpec("dynamics", "scale", {"param": "gravity", "factor": 1.2}),
    ShiftSpec("dynamics", "scale", {"param": "actuator_gear", "index": "all", "factor": 0.8}),
], seed=0)
env.reset(seed=0)
model = env.unwrapped.model
print(round(model.opt.gravity[2], 3), model.actuator_gear[:, 0])
-11.772 [160. 160. 160.]
The names a task accepts are listed by its adapter.
from robustrllib.adapters import get_adapter

names = get_adapter(make_robust("Hopper-v5")).list_params()
Rules
- A parameter of one entity is always written with
index; withoutindexthe shift addresses entity 0, which for MuJoCo bodies is the world body. - A factor is relative to the nominal value, so repeated resets do not compound it.
- One parameter and index is addressed by one shift only; of two shifts on the same parameter the later one wins.
- A parameter whose nominal value is zero is randomized with
operation: setand anominal. translateis written for position vectors:body_pos_xyz,freejoint_pos,cam_posandlight_pos.- The drawn mode names are not combined with a schedule, because they would then draw at every step.
push,transitionandtranslateneed a MuJoCo task.